Remote operations shadow robots stage 1
01 January 2022
Focus area: Traceability and integrity systems
Program stream: Growth and global competitiveness
Project number: 2021-1058
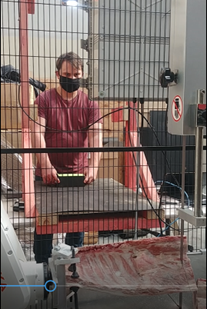
The system that was set up included a robot positioned adjacent to the bandsaw where the meat to be cut was held by the robot. The position of the robot was controlled by an operator situated at an operator’s workspace out of reach of the robot and bandsaw. The operator moved a tracked object within the operator’s workspace. The robot end-effector “shadows” the motion of the tracked object in real-time so that the operator can manipulate the meat to be cut by the bandsaw.
The proof of concept was successfully completed, and early results show that the cutting is accurate, and beef racks can be cut in under a minute.
A provisional patent has been filed for this concept.